Skyclient

One client for the whole aircraft

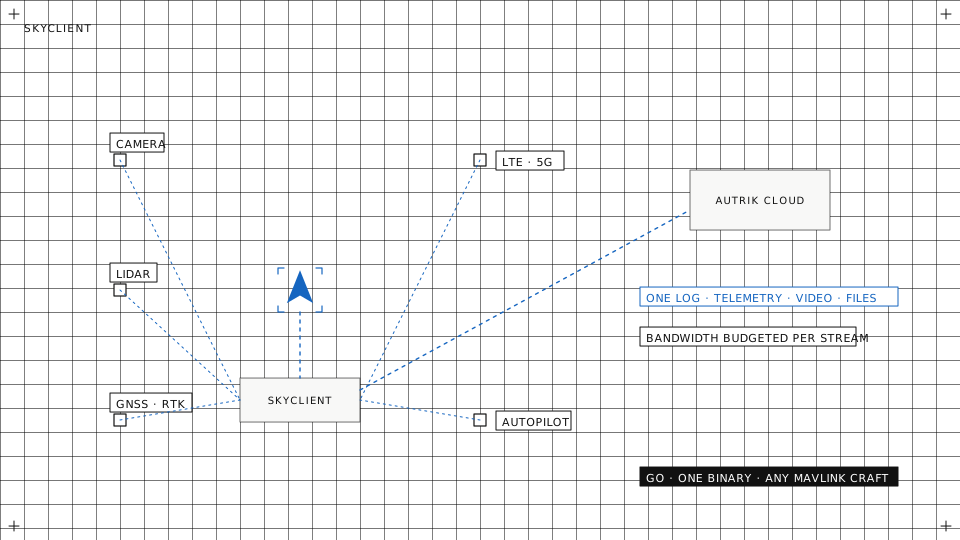
One software to manage every aspect of the drone and its peripherals — diagnostics, telemetry, stream management and automation in a single onboard client. Not another flight log: a timestamped view of everything happening on the vehicle.

Plan map: one client on the companion computer linking the aircraft's sensors and links to the cloud
Intelligent diagnostics

One holistic log, not five partial ones

When what happened

Root-cause analysis fails when the evidence is scattered across a tlog, a flight-stack log, and whatever the modem remembered. Skyclient records the whole aircraft on one timeline.
  • Holistic timestamped logAutopilot, cameras, gimbal, modem and companion computer on a single timeline, so "when what happened" is a question you can actually answer.
  • Raw MAVLink dumpFull MAVLink message logging when you need to see the wire, not a summary of it — the deep-debugging escape hatch.
  • Log levelsQuiet in normal operation, verbose when you are chasing something. Set the level per deployment rather than per rebuild.
Holistic log
THREE PARTIAL RECORDSAUTOPILOTCAMERASGIMBALMODEMCOMPANIONtlogflight-stack logwhat the modem rememberedno recordno recordno recordMAVLINK RAWtONE CLOCKwhen what happenedLOG LEVELquietverboseset per deployment, not per rebuild
The evidence sits in a tlog, a flight-stack log and whatever the modem remembered. Cameras, gimbal and companion computer left nothing beside them.
Real-time

Fault detection while it is still flying

Telemetry streaming with in-house anomaly detection — problems surface during the flight, not during the post-mortem.

Anomaly detection

In-house algorithms watch the live telemetry stream and flag behaviour that departs from the aircraft's own normal.
Peripheral health

Per-device state for modem, cameras and sensors, including an end-to-end connectivity check — not just "the process is running".

Beyond a tlog

A far more detailed view than a tlog or flight-stack log gives you, because it covers the payload and the link as well as the autopilot.

Device · Skyclient tab: system metrics, modules, logs

Stream management

Bandwidth is the scarce resource

Many sensors, one link

A modern aircraft carries FPV video, a mapping camera, a gimbal and often an AI accelerator. Managing those streams is what decides whether the link holds.
  • Budget across streamsPrioritise and cap bandwidth and onboard compute per stream, so the feed that matters for this mission is the one that survives.
  • Per-peripheral controlStart, stop and reconfigure individual streams in flight without restarting the whole payload stack.
  • Custom peripheralsMany devices are supported out of the box, and adding your own is a documented extension path rather than a fork.
Stream budget
ONBOARDFPV VIDEOMAPPING CAMERAGIMBALAI ACCELERATORGIMBALYOUR DEVICESKYCLIENTcappedreconfigured in flightpriority · this missioncappedstopped in flightcappeddocumented extension pathONE LINKGROUNDBANDWIDTHCOMPUTEFPVMAPGIMAIFPVMAPGIMAIMAPFPVGIMAIMAPFPVGIMAIMAPFPVAIMAPFPVAIMAPFPVAIYOUMAPFPVAIYOUOVEROVERlimit
FPV video, a mapping camera, a gimbal and an AI accelerator all want the one link and the onboard compute. Unmanaged, the link does not hold.
Automation

Behaviour you can rely on

Custom actions

"If this happens, then do this" — encode the responses your team already performs by hand into the aircraft itself.

Enforceable checklists

Checklists the aircraft actually enforces, so a step is completed rather than remembered. Repeatable operations, provably.

One client, whole fleet

The same onboard client across aircraft types, so operational behaviour does not drift between platforms.

Simulation · one agent, each robot on its vendor’s own interface: Scout over CAN, Go2 over DDS, Spot, Panther over ROS 2

See what your aircraft is really doing

Talk to us about running Skyclient on your platform, or see which sensors are supported today.